Stores the abs-normal form in sparse format. More...
#include <sparsematrix.h>
Public Types | |
| using | Shape = SparseShape |
Public Member Functions | |
| ~SparseANF ()=default | |
| SparseANF ()=default | |
| SparseANF (Shape dims) | |
| SparseANF (SparseANF &&)=default | |
| SparseANF & | operator= (SparseANF &&)=default |
| SparseANF (const SparseANF &)=default | |
| SparseANF & | operator= (const SparseANF &)=default |
| bool | empty () const |
| Check whether all sparse blocks and dense vectors are empty. | |
| void | clear () |
| Clear all sparse blocks and dense vectors. | |
| Shape | dims () const |
| void | updateCy () |
Compute cy = y - J|z| from the current data. | |
| void | updateCz () |
Compute cz = z - L|z| from the current data. | |
| void | resize (Shape dims) |
| Resize sparse blocks according to the given block counts. | |
Public Attributes | |
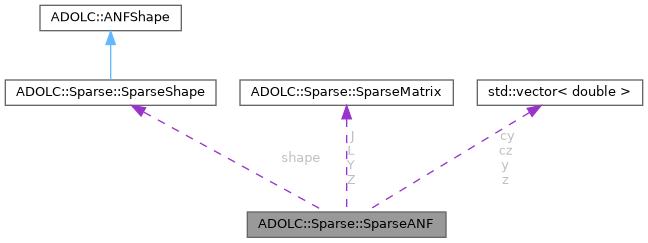
| Shape | shape {} |
| SparseMatrix | Y |
Output Jacobian block Y = dy / dx. | |
| SparseMatrix | J |
Output block J = dy / d|z|. | |
| SparseMatrix | Z |
Switching-equation Jacobian block Z = dz / dx. | |
| SparseMatrix | L |
Switching-equation block L = dz / d|z|. | |
| std::vector< double > | cz |
| Constant term of the switching equations. | |
| std::vector< double > | cy |
| Constant term of the dependent equations. | |
| std::vector< double > | y |
| Dependent values at the evaluation point. | |
| std::vector< double > | z |
| Switching-variable values at the evaluation point. | |
Detailed Description
Stores the abs-normal form in sparse format.
This type is intended to satisfy the full AbsNormalFormType interface.
The piecewise-linear sparse drivers recover the extended Jacobian [Y J; Z L]. This type groups the four coordinate-format blocks in that same order inside one owning object. Entries inside each block use block-local coordinates, i.e. Y and J use dependent row indices, Z and L use switching row indices, Y and Z use independent column indices, and J and L use switching-variable column indices.
The dense vectors cy and cz store the abs-normal constants associated with y and z. They are computed by the sparse piecewise-linear driver together with the four Jacobian blocks.
Member Typedef Documentation
◆ Shape
Constructor & Destructor Documentation
◆ ~SparseANF()
|
default |
◆ SparseANF() [1/4]
|
default |
◆ SparseANF() [2/4]
|
inlineexplicit |
◆ SparseANF() [3/4]
|
default |
◆ SparseANF() [4/4]
|
default |
Member Function Documentation
◆ clear()
|
inline |
Clear all sparse blocks and dense vectors.
◆ dims()
|
inline |
◆ empty()
|
inline |
Check whether all sparse blocks and dense vectors are empty.
◆ operator=() [1/2]
◆ operator=() [2/2]
◆ resize()
|
inline |
Resize sparse blocks according to the given block counts.
- Parameters
-
dims Number of entries in each sparse block.
◆ updateCy()
|
inline |
Compute cy = y - J|z| from the current data.
◆ updateCz()
|
inline |
Compute cz = z - L|z| from the current data.
Member Data Documentation
◆ cy
| std::vector<double> ADOLC::Sparse::SparseANF::cy |
Constant term of the dependent equations.
◆ cz
| std::vector<double> ADOLC::Sparse::SparseANF::cz |
Constant term of the switching equations.
◆ J
| SparseMatrix ADOLC::Sparse::SparseANF::J |
Output block J = dy / d|z|.
◆ L
| SparseMatrix ADOLC::Sparse::SparseANF::L |
Switching-equation block L = dz / d|z|.
◆ shape
| Shape ADOLC::Sparse::SparseANF::shape {} |
◆ Y
| SparseMatrix ADOLC::Sparse::SparseANF::Y |
Output Jacobian block Y = dy / dx.
◆ y
| std::vector<double> ADOLC::Sparse::SparseANF::y |
Dependent values at the evaluation point.
◆ Z
| SparseMatrix ADOLC::Sparse::SparseANF::Z |
Switching-equation Jacobian block Z = dz / dx.
◆ z
| std::vector<double> ADOLC::Sparse::SparseANF::z |
Switching-variable values at the evaluation point.
The documentation for this struct was generated from the following file: